

Inertial Measurement Unit (IMU) Devices
LPMS inertial measurement units (IMU) combine a 3-axis gyroscope, accelerometer and magnetometer with on-board sensor fusion, so every unit is also an attitude and heading reference system (AHRS) that outputs roll, pitch and yaw, quaternions, linear acceleration and raw data over the interface you need: USB, CAN bus, RS232, RS485, TTL / UART, Bluetooth or Wi-Fi. The range runs from a 2 g OEM module to IP67 industrial sensors, a navigation IMU with a dedicated heading gyroscope, a GNSS-integrated unit and a precision inclinometer, all sharing the IMUcore fusion algorithm, LPMS-Control2 configuration software and OpenZen / ROS drivers. New to inertial sensing? Start with What is an IMU? and How to choose an IMU.
High Performance IMUs
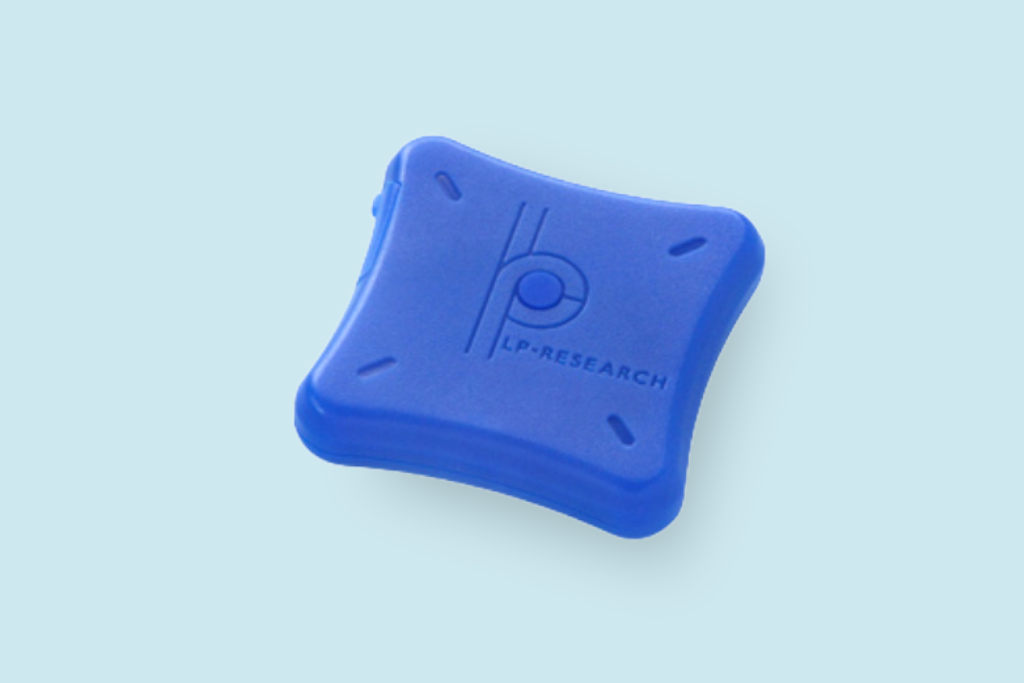 LPMS-B2 Series - 3D inertial measurement unit (IMU / AHRS) · Wireless connectivity (Bluetooth 2.1 / BLE) · Internal flash memory data recording
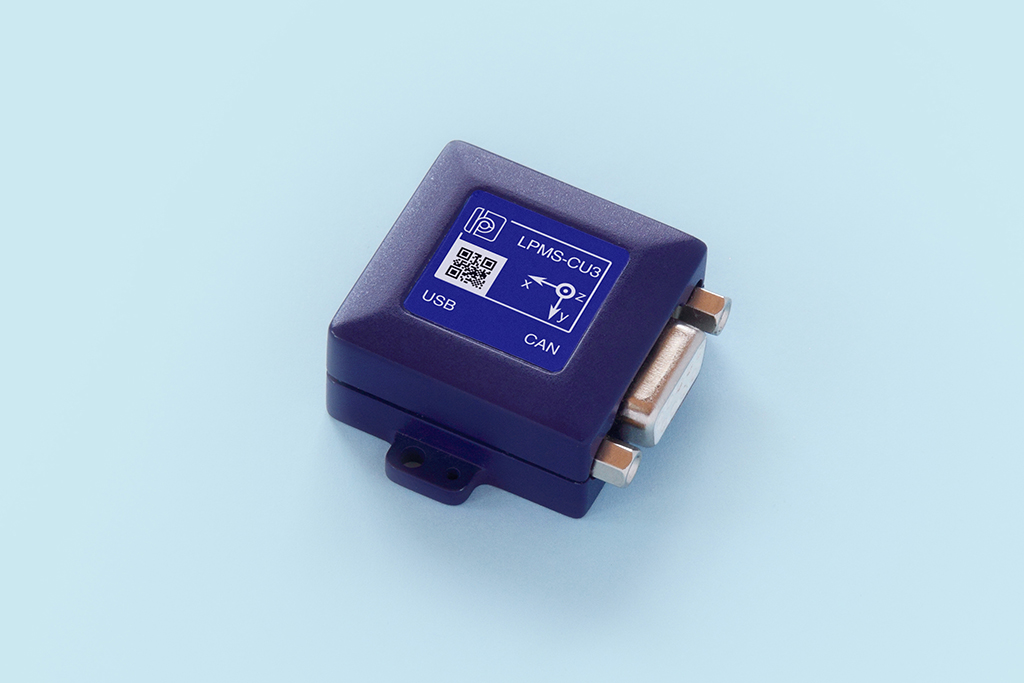 LPMS-U3 Series - 3D inertial measurement unit (IMU / AHRS) · USB, CAN Bus, RS232 or TTL interface · Robust and light plastic enclosure
 LPMS-AL3 Series - 3D inertial measurement unit (IMU / AHRS) · USB, CAN Bus, RS232 or TTL interface · IP67 rugged waterproof housing
Industrial Grade IMUs
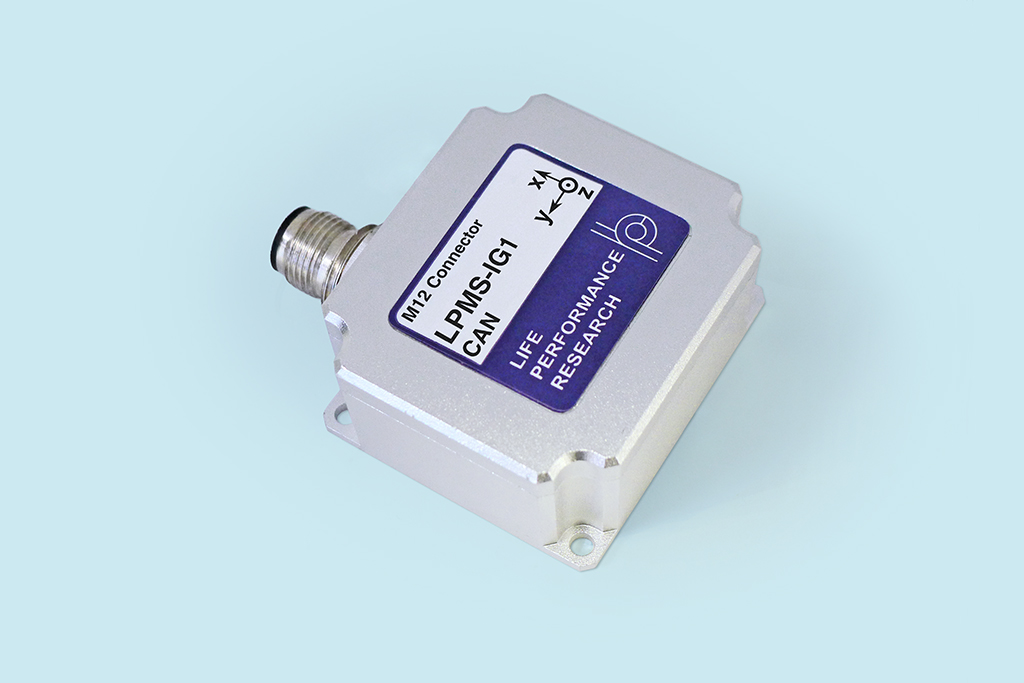 LPMS-IG1 Series - 9-axis IMU/AHRS with USB/CAN/RS232 connectivity · High precision dual gyroscopes for range flexibility
 LPMS-IG1P Series - 9-axis IMU/AHRS with USB/CAN/RS232 connectivity · GPS receiver, optionally RTK-GPS for localization
 LPMS-IG1W - 9-axis IMU/AHRS with wireless/USB connectivity · Wi-Fi wireless communication for industrial IoT applications
 LPMS-NAV3 Series - 6-axis IMU with high accuracy heading measurement · 3 axis accelerometer/gyroscope + 1 axis high accuracy gyroscope for heading measurement
 LPMS-HR Series - High-precision MEMS IMU for robotics and autonomous platforms · Real-time 6-DOF orientation output via USB, RS232, or TTL
Board Level High Performance IMUs
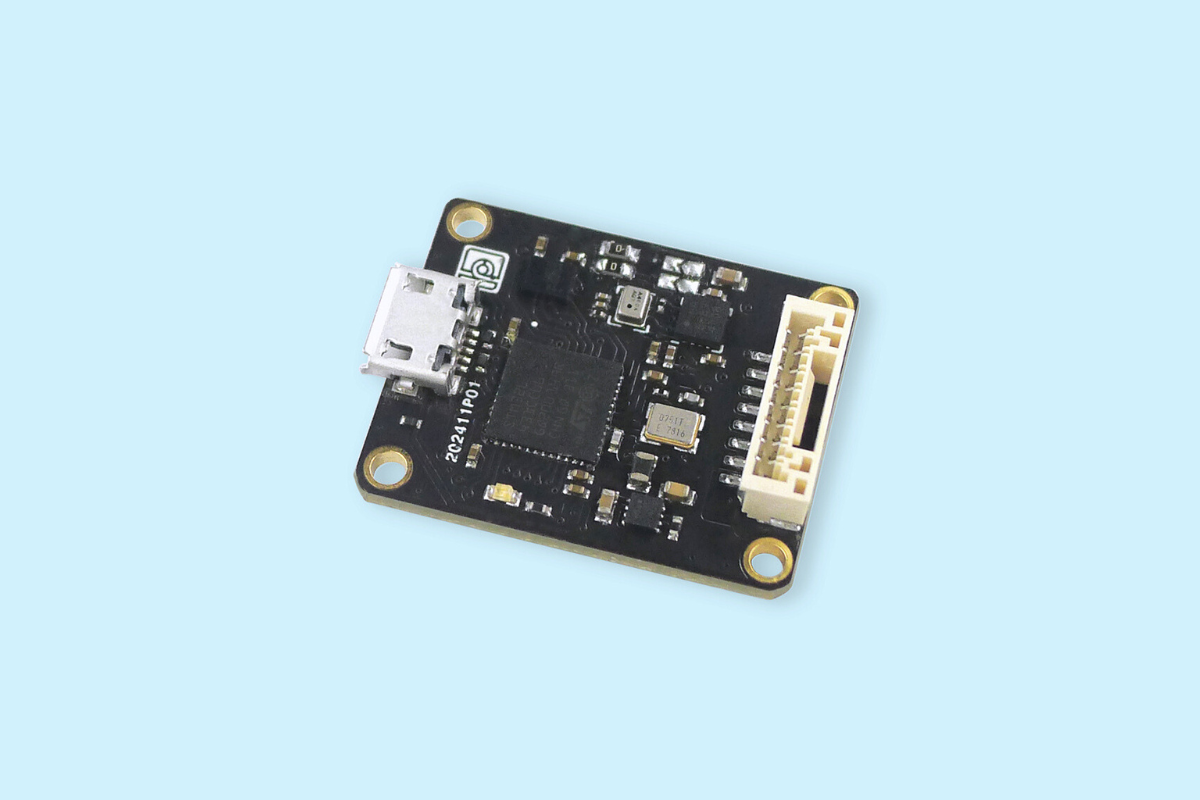 LPMS-CURS3 - 3D inertial measurement unit (IMU / AHRS) · USB interface + CAN bus or serial interface · PCB version without enclosure
High Performance Inclinometer Sensor
 LPMS-INC1 - High-precision dual-axis MEMS inclinometer · Multiple communication interfaces (RS232 / CAN / RS485 / TTL) · Industrial IP67-rated aluminum housing
Compare LPMS IMU models
| Model | Sensors, rate, static accuracy | Interfaces | Housing, size, weight | Typical use |
|---|---|---|---|---|
| LPMS-B2 | 9-axis + barometer · 400 Hz · < 0.5° | Bluetooth Classic 2.1, BLE 4.1 | Plastic · 39 × 39 × 8 mm · 12 g (OEM 2 g) | Wearables, motion capture, AR / VR |
| LPMS-U3 | 9-axis + barometer · 500 Hz · < 0.5° | USB + CAN, RS232 or TTL | Plastic · 34 × 34.5 × 15.7 mm · 17.6 g | Robotics, machine tracking, research |
| LPMS-CURS3 | 9-axis + barometer · 500 Hz · < 0.5° | USB + CAN, RS232 or TTL | Bare PCB · 22 × 28 × 7.65 mm · 4 g | OEM integration |
| LPMS-AL3 | 9-axis · 500 Hz · < 0.5° | CAN, RS232 or TTL, plus USB | IP67 aluminium · 50 × 42 × 25 mm · 107 g | Industrial and outdoor machinery |
| LPMS-IG1 | 9-axis, dual gyroscopes · 500 Hz · < 0.3° | USB + CAN, RS232 or RS485 | IP67 aluminium · 51 × 45 × 24 mm · 74-114 g | High-precision tracking, AGV dead reckoning |
| LPMS-IG1P | 9-axis + GNSS (25 Hz) · 500 Hz · < 0.26° roll, < 0.18° pitch | USB + CAN, RS232 or RS485 | IP67 aluminium · 51 × 45 × 24 mm · 118 g | Outdoor navigation, vehicles, AGVs |
| LPMS-IG1W | 9-axis, dual gyroscopes · 500 Hz · < 0.3° | Wi-Fi (TCP/IP, MQTT) + USB | IP67 aluminium · 51 × 45 × 24 mm · 115 g | Wireless industrial IoT, vibration monitoring |
| LPMS-NAV3 | 6-axis + 24-bit heading gyroscope · 500 Hz | RS232, RS485, RS422, TTL or CAN | IP67 aluminium · 50 × 42 × 25 mm · 107 g | AGV and mobile robot heading |
| LPMS-HR | 6-axis, 16-bit · 1000 Hz · 0.01° resolution | USB, RS232 or TTL | Aluminium · 22.4 × 22.4 × 11 mm | Humanoid and legged robot control |
| LPMS-INC1 | Dual-axis inclinometer · 500 Hz · 0.011° RMS | RS232 or CAN | IP67 aluminium · 74 × 40 × 28.5 mm · 184 g | Tilt monitoring, construction, energy |
Dynamic accuracy is < 2° RMS for the standard 9-axis models and < 1° RMS for the LPMS-IG1 and LPMS-IG1W. All models output raw data, Euler angles and quaternions at configurable rates; datasheets are linked on each product page. Legacy models still documented: LPMS-U2 and LPMS-ME1.
Which IMU do I need?
- Body-worn or cable-free: LPMS-B2 (Bluetooth, up to 7 units per host) or LPMS-IG1W (Wi-Fi, IP67).
- Wired, compact, on a bench or inside a machine: LPMS-U3, or the bare-board LPMS-CURS3 for your own PCB or enclosure.
- Wet, dusty or vibrating environments: LPMS-AL3, LPMS-IG1 or LPMS-NAV3 in IP67 aluminium with M12 connectors.
- Heading that stays put on a mobile robot or AGV: LPMS-NAV3, whose dedicated single-axis gyroscope is built for yaw.
- Fast control loops on humanoid or legged robots: LPMS-HR at 1000 Hz.
- Absolute position outdoors: LPMS-IG1P with multi-constellation GNSS and IMU / odometry dead reckoning.
- Tilt only: LPMS-INC1.
The full decision process, including interface protocols and software support, is in How to choose an IMU. If you are new to inertial sensing, start with What is an IMU?.
Where to buy
LPMS sensors ship directly from LP-Research in Tokyo and through our distributors in Europe, Asia and the Americas; Xikaku serves the United States from xikaku.com. For quotations, evaluation units, OEM volumes and custom firmware, contact us.